MR-EM340GF Mitsubishi Motion controller Embedded Type Servo System Controller
Request a Quote

Quick facts
| Availability | Confirmed on request |
| Category | Mitsubishi Motion controller – Embedded Type Servo System Controller |
| Lifecycle | Active mature |
| Warranty | 12-month (new) · 3-month (used/refurbished) |
Shipping & availability
When can MR-EM340GF be shipped?
MR-EM340GF is sourced on request — request a quote and we'll confirm the exact availability and shipping timeline for this specific unit.
Can I pick up MR-EM340GF in person?
Local pickup from our Groningen, Netherlands warehouse may be possible — contact us before ordering to check availability and arrange a collection time.
Is express delivery available?
Yes — mention it when you request a quote for MR-EM340GF and we'll include express shipping options in our reply.
My factory is down and I need this urgently — can you help?
For a critical breakdown, contact us directly at +31 (0)50-7110348 or sales@partnerplc.com — we can look into same-day courier or dedicated taxi/hotshot delivery for MR-EM340GF, subject to availability and destination.
The Mitsubishi Electric MR-EM340GF is a embedded Type Servo System Controller in the Motion controller. Simple Motion board, Up to 16 axes. Mitsubishi Electric has announced its discontinuation (2028/03 To be end of order) — plan spares now; PartnerPLC also sources it on the surplus market after the end of order. Specifications and manuals below are Mitsubishi Electric's own data.
Specifications
Product
| Series | Motion controller |
| Category | Embedded Type Servo System Controller |
| Type | Simple Motion board |
| Sales status | 2028/03 To be end of order (Mitsubishi Electric) |
| Outline | Simple Motion board, Up to 16 axes |
Control specifications
| Maximum number of control axes (virtual servo amplifier axis included) | 16 axes |
| Operation cycle (operation cycle settings) | 0.5 ms, 1.0 ms, 2.0 ms, 4.0 ms |
| Interpolation function | Linear interpolation (up to 4 axes), 2-axis circular interpolation, helical interpolation (3 axes) |
| Control method | Positioning control, path control (linear, arc, and helical), speed control, speed-torque control |
| Acceleration/deceleration processing | Trapezoidal acceleration/deceleration, S-curve acceleration/deceleration |
| Compensation function | Backlash compensation, electronic gear, near pass function |
| Synchronous control | Synchronous encoder input, cam, phase compensation, cam auto-generation |
| Control unit | mm, inch, degree, pulse |
| Number of positioning data | 600 data/axis |
| Backup | Parameters, positioning data, and block start data can be saved on flash ROM (batteryless backup) |
| Home position return: Home position return method | Driver home position return |
| Home position return: Fast home position return control | Provided |
| Home position return: Auxiliary function | Provided (using sub-function of servo amplifier) |
| Positioning control: Linear control | Linear interpolation (Up to 4 axes) *1 (vector speed, reference axis speed) |
| Positioning control: Fixed-pitch feed | Fixed-pitch feed control |
| Positioning control: 2-axis circular interpolation | auxiliary point-specified, central point-specified |
| Positioning control: Speed control | Speed control |
| Positioning control: Speed-position switching | INC mode, ABS mode |
| Positioning control: Position-speed switching | INC mode |
| Positioning control: Current value change | Positioning data, start No. for a current value changing |
| Positioning control: NOP instruction | Provided |
| Positioning control: JUMP instruction | Conditional, unconditional |
| Positioning control: LOOP, LEND | Provided |
| Positioning control: High-level positioning | Block start, condition start, wait start, simultaneous start, repeated start |
| Manual control: JOG operation | Provided |
| Manual control: Inching operation | Provided |
| Manual control: Manual pulse generator | Possible to connect 1 module (incremental), unit magnification (1 to 10000 times) Via a link device |
| Expansion control: Speed-torque control | Speed control not including position loop, torque control |
| Expansion control: Direct control | Provided |
| Absolute position system | Provided (Made compatible by setting battery to servo amplifier.) |
| Synchronous encoder interface | 16 channels |
| Synchronous encoder interface: Via buffer memory | Provided (incremental) |
| Synchronous encoder interface: Link device | Provided (incremental) |
| Synchronous encoder interface: Via servo amplifier | 16 channels |
| Functions that limit control: Speed limit | Speed limit value, JOG speed limit value |
| Torque limit function | Torque limit value same setting, torque limit value individual setting |
| Functions that limit control: Forced stop: Internal interface | Provided |
| Functions that limit control: Forced stop: Via buffer memory | Provided |
| Functions that limit control: Forced stop: Via link device | Provided |
| Functions that limit control: Software stroke limit | Movable range check with current feed value, movable range check with machine feed value |
| Functions that limit control: Hardware stroke limit | Provided |
| Functions that change control details: Speed change | Provided |
| Functions that change control details: Override | 0 to 300 % |
| Functions that change control details: Acceleration/deceleration time change | Provided |
| Functions that change control details: Torque change | Provided |
| Functions that change control details: Target position change | Speed to a target position address and a target position is changeable. |
| Other functions: M-code output | WITH mode/AFTER mode |
| Step function | Deceleration unit step, data No. unit step |
| Other functions: Skip function | Via a buffer memory or an external command signal |
| Teaching function | Provided |
| Parameter initialization function | Provided |
| External input signal setting function: Via buffer memory | Provided |
| External input signal setting function: Link device | Provided |
| External input signal setting function: Via servo amplifier | Provided |
| Amplifier-less operation function (virtual servo amplifier function) | Provided |
| Mark detection function | Continuous detection mode, specified number of detections mode, ring buffer mode |
| Mark detection function: Mark detection signal | Up to 16 points *3 |
| Mark detection function: Mark detection setting | 16 settings |
| Digital oscilloscope function *2: Bit data | 16 channels |
| Digital oscilloscope function *2: Word data | 16 channels |
Simple Motion board specifications
| Servo amplifier connection method | CC-Link IE Field Network |
| Maximum distance between stations [m] | 100 |
| PERIPHERAL I/F | Ethernet (100BASE) |
| Forced stop input signal (EMI): Number of input points | 1 point |
| Forced stop input signal (EMI): Input method | Positive common/negative common shared type (photocoupler isolation) |
| Forced stop input signal (EMI): Rated input voltage/current | 24 V DC/Approx. 2.4 mA |
| Forced stop input signal (EMI): Operating voltage range | 20.4 V DC to 26.4 V DC (24 V DC +10 %/-15 %, ripple ratio 5 % or less) |
| Forced stop input signal (EMI): ON voltage/current | 17.5 V DC or more/2.0 mA or more |
| Forced stop input signal (EMI): OFF voltage/current | 1.8 V DC or less/0.18 mA or less |
| Forced stop input signal (EMI): Input resistance | Approx. 10 kΩ |
| Forced stop input signal (EMI): Response time | 1 ms or less (OFF to ON, ON to OFF) |
| Forced stop input signal (EMI): Applicable wire size [mm 2 ] | 0.08 to 0.5 (AWG 20 to AWG 28) |
| Number of Simple Motion boards for one computer | 4 |
| Bus specification | PCI Express ® 2.0 × 1 |
| Bus specification: Size [mm] | Short size (167.65 × 111.15) |
| Power supply voltage | 12 V DC/3.3 V DC |
| Current consumption [A]: 12 V DC | 0.4 |
| Current consumption [A]: 3.3 V DC | 0.6 |
| Mass [kg] | 0.13 |
Downloads & documentation
Official documents from Mitsubishi Electric (Factory Automation), downloaded directly from the manufacturer.
Data sheets & manuals
More Mitsubishi Electric (Factory Automation) parts
 Available on requestMR-EKCBL30M-L Mitsubishi MELSERVO servo Encoder cable
 Available on requestMR-EKCBL40M-H Mitsubishi MELSERVO servo Encoder cable
 Available on requestMR-EKCBL50M-H Mitsubishi MELSERVO servo Encoder cable
 Available on requestMR-EKCBL5M-H Mitsubishi MELSERVO servo Encoder cable
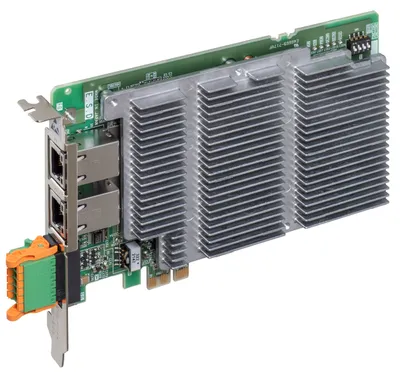 Available on requestMR-EM441G Mitsubishi Motion controller Embedded Type Servo System Controller
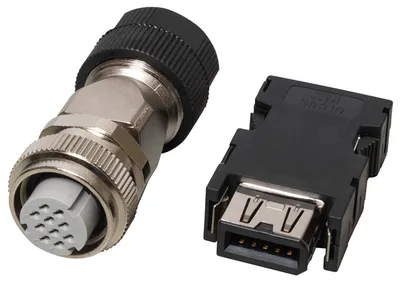 Available on requestMR-ENCNS2 Mitsubishi MELSERVO servo Encoder connector set (screw type)
 Available on requestMR-ENCNS2A Mitsubishi MELSERVO servo Encoder connector set (screw type)
 Available on requestMR-ENE4CBL10M-H-MTH Mitsubishi MELSERVO servo Encoder cable