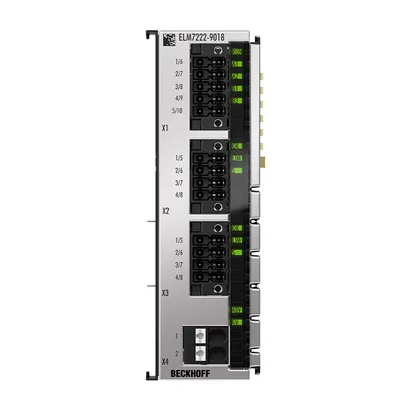
Beckhoff
ELM7222-9018EtherCAT Terminal, 2-channel motion interface, servomotor, 48 V DC, 8 A, OCT, STO, Safe Motion, TwinSAFE Logic
We source discontinued Siemens parts on the surplus market, tested and with warranty.
Request a quote
We source discontinued B&R parts on the surplus market, tested and with warranty.
Request a quote
We source discontinued ABB parts on the surplus market, tested and with warranty.
Request a quote
We source discontinued Schneider Electric parts on the surplus market, tested and with warranty.
Request a quote
We source discontinued Allen-Bradley parts on the surplus market, tested and with warranty.
Request a quote
We source discontinued Mitsubishi Electric parts on the surplus market, tested and with warranty.
Request a quote
We source discontinued Beckhoff parts on the surplus market, tested and with warranty.
Request a quote
We source discontinued Lenze parts on the surplus market, tested and with warranty.
Request a quote
We source discontinued Bosch Rexroth parts on the surplus market, tested and with warranty.
Request a quote
We source discontinued Danfoss parts on the surplus market, tested and with warranty.
Request a quote
We source discontinued SEW-Eurodrive parts on the surplus market, tested and with warranty.
Request a quote
We source discontinued KUKA parts on the surplus market, tested and with warranty.
Request a quote
We source discontinued Omron parts on the surplus market, tested and with warranty.
Request a quote
We source discontinued Festo parts on the surplus market, tested and with warranty.
Request a quote
We source discontinued WAGO parts on the surplus market, tested and with warranty.
Request a quote
We source discontinued Pilz parts on the surplus market, tested and with warranty.
We source discontinued SICK parts on the surplus market, tested and with warranty.
Request a quote
We source discontinued Pepperl+Fuchs parts on the surplus market, tested and with warranty.
Request a quote
We source discontinued Balluff parts on the surplus market, tested and with warranty.
Request a quote
We source discontinued ifm parts on the surplus market, tested and with warranty.
Request a quoteWe source discontinued Banner parts on the surplus market, tested and with warranty.
Request a quote
We source discontinued Keyence parts on the surplus market, tested and with warranty.
Request a quote
We source discontinued Honeywell parts on the surplus market, tested and with warranty.
Request a quote
We source discontinued Infineon parts on the surplus market, tested and with warranty.
Request a quoteEtherCAT Terminal, 2-channel motion interface, servomotor, 48 V DC, 8 A, OCT, STO, Safe Motion, TwinSAFE Logic
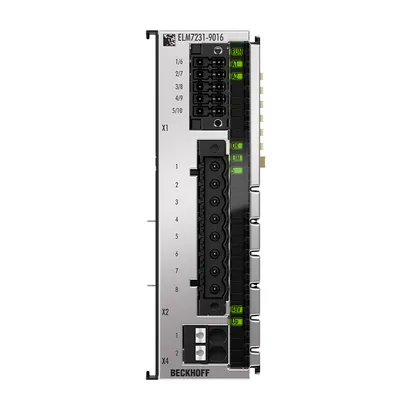
EtherCAT Terminal, 1-channel motion interface, servomotor, 48 V DC, 16 A, OCT, STO, TwinSAFE Logic
EtherCAT Terminal, 1-channel motion interface, servomotor, 48 V DC, 16 A, OCT, STO, Safe Motion, TwinSAFE Logic
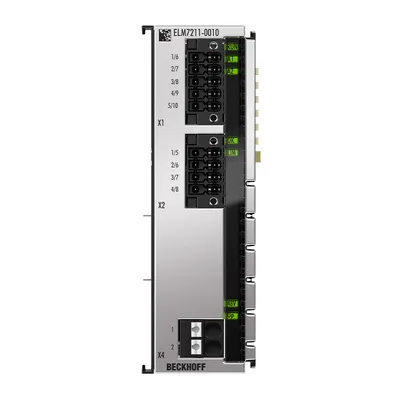
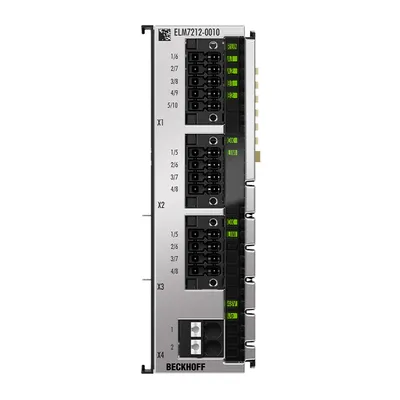
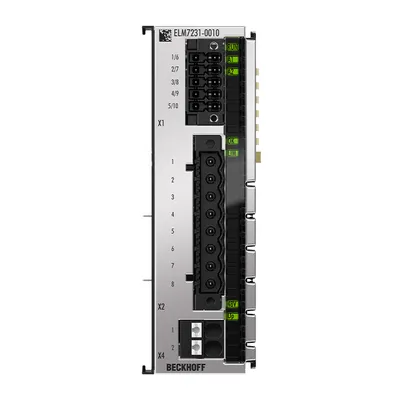
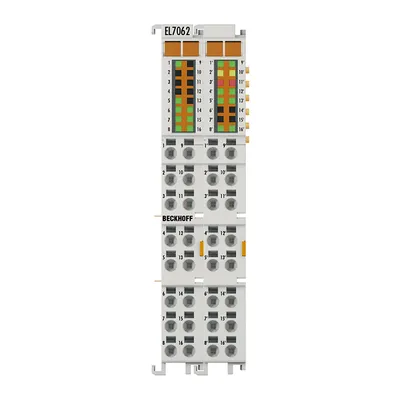
EtherCAT Terminal, 2-channel motion interface, stepper motor, 48 V DC, 3 A, with incremental encoder, 5 V DC
Key specifications of the parts listed on this page, taken from the manufacturer's data sheets.
| MPN | Number of inputs | Output current (rms) | Peak current (rms) | Power loss | Current consumption E-bus |
|---|---|---|---|---|---|
| ELM7222-9018 | 4 x digital input, 2 x feedback | 2 x 8 A | max. 2 x 16 A for 1 s | typ. 10 W | 120 mA |
| ELM7231-9016 | 2 x digital input, 1 x feedback | 16 A | max. 30 A for 1 s | typ. 10 W | 120 mA |
| ELM7231-9018 | 2 x digital input, 1 x feedback | 16 A | max. 30 A for 1 s | typ. 10 W | 120 mA |
| ELM7211-0010 | 2 x digital input, 1 x feedback | 4.5 A | max. 9.0 A for 1 s | typ. 5 W | 120 mA |
| ELM7212-0010 | 4 x digital input, 2 x feedback | 2 x 4.5 A | max. 2 x 9.0 A for 1 s | typ. 7,5 W | 120 mA |
| ELM7221-0010 | 2 x digital input, 1 x feedback | 8 A | max. 16 A for 1 s | typ. 5 W | 120 mA |
| ELM7222-0010 | 4 x digital input, 2 x feedback | 2 x 8 A | max. 2 x 16 A for 1 s | typ. 10 W | 120 mA |
| ELM7231-0010 | 2 x digital input, 1 x feedback | 16 A | max. 30 A for 1 s | typ. 10 W | 120 mA |
| EL7062 | 2 latch inputs, 2 x encoder | — | — | — | typ. 175 mA |
| Technology | compact drive technology |
| Supply voltage electronics | 24 V DC (via power contacts) |
| Supply voltage power | 8…48 V DC (external) |
| Current controller frequency | 32 kHz |
| Distributed clocks | yes |
| Electrical isolation | 500 V (E-bus/field potential) |
| Operating temperature | 0…55°C |
| Storage temperature | -25…+85°C |