MR-MC341 Mitsubishi Motion controller Embedded Type Servo System Controller
Request a Quote

Quick facts
| Availability | Confirmed on request |
| Category | Mitsubishi Motion controller – Embedded Type Servo System Controller |
| Lifecycle | Active |
| Warranty | 12-month (new) · 3-month (used/refurbished) |
Shipping & availability
When can MR-MC341 be shipped?
MR-MC341 is sourced on request — request a quote and we'll confirm the exact availability and shipping timeline for this specific unit.
Can I pick up MR-MC341 in person?
Local pickup from our Groningen, Netherlands warehouse may be possible — contact us before ordering to check availability and arrange a collection time.
Is express delivery available?
Yes — mention it when you request a quote for MR-MC341 and we'll include express shipping options in our reply.
My factory is down and I need this urgently — can you help?
For a critical breakdown, contact us directly at +31 (0)50-7110348 or sales@partnerplc.com — we can look into same-day courier or dedicated taxi/hotshot delivery for MR-MC341, subject to availability and destination.
The Mitsubishi Electric MR-MC341 is a embedded Type Servo System Controller in the Motion controller. Position board, Up to 64 axes, PCI Express ®. Specifications and manuals below are Mitsubishi Electric's own data.
Specifications
Product
| Series | Motion controller |
| Category | Embedded Type Servo System Controller |
| Type | Position board |
| Outline | Position board, Up to 64 axes, PCI Express ® |
Control specifications
| System functions: Number of control axes | Up to 64 axes |
| System functions: Control cycle | 0.22 ms, 0.44 ms, 0.88 ms (Select using parameters.) |
| System functions: Control mode | Positioning control, continuous operation to torque control |
| Operation functions *1 *2: JOG operation | Provided |
| Operation functions *1 *2: Incremental feed | Provided |
| Operation functions *1 *2: Automatic operation | Point table method, 1 axis control, continuous operation to torque control |
| Operation functions *1 *2: Linear interpolation | Point table method, interpolation control of up to 4 axes is available *3 |
| Operation functions *1 *2: Circular interpolation | Provided |
| Operation functions *1 *2: Home position return | Dog method, dog cradle method, dog front end method, data set method, continuous operation to torque control method, Z-phase detection method, limit switch combined method, limit switch front end method, scale home position signal detection method, scale home position signal detection method 2, home position reset (data set) |
| Application functions 1: Electronic gear | Electronic gear numerator: 1 to 5242879 Electronic gear denominator: 1 to 589823 |
| Application functions 1: Speed units | Command unit/min, command unit/s, r/min |
| Application functions 1: Acceleration/deceleration | Command speed limits: 1 to speed limit Limit of start speed: 1 to speed limit Time constant limits: 0 to 20000 ms Separate setting of constants for deceleration and acceleration: provided Setting of constants for separate points: provided Acceleration/deceleration method: linear acceleration/deceleration, smoothing filter, start up speed, S-curve acceleration/deceleration (sine acceleration/decele |
| Application functions 1: Stop function | Forced stop, stop operation, rapid stop operation |
| Application functions 1: Command change | Location, speed, time constant |
| Application functions 2 | Hardware stroke limit, software stroke limit, interlock, rough match output, torque limit, backlash compensation, position switch, interference check *3 , home position search limit, gain switching, PI-PID switching, absolute position detection system, home position return request, other axes start, digital I/O, servo amplifier general I/O, pass position interrupt, tandem drive, mark detection |
| Auxiliary function 1: Monitor | Current command position, current feedback position, speed command, position droop, electrical current command, servo alarm number, external signal status, etc. |
| Auxiliary function 1: High speed monitor | Current command position, current feedback position, moving speed, feedback moving speed, external signal, electrical current feedback |
| Auxiliary function 1: Interrupt | During start operation/operation stoppage (during operation, in-position, during smoothing of stopping, rough match, etc.), when alarm goes off (servo alarm/operation alarm), etc. |
| Auxiliary function 1: Host PC watchdog | Provided (for the watchdog of the user program CPU) |
| Auxiliary function 1: Parameter backup | Parameters are saved to the flash ROM. |
| Auxiliary function 1: Test mode | Servo amplifier tests are easily enabled by connecting MR Configurator2 via a controller. |
| Auxiliary function 1: Connect/disconnect | Provided |
| Auxiliary function 1: Sampling | Maximum sampling point: 65536 |
| Auxiliary function 1: Log | History of start operation, alarms, etc., are recorded. |
| Auxiliary function 1: Alarm history | Provided |
| Auxiliary function 1: External forced stop disabled | Provided |
| Board ID | 0 to 3 |
Control specifications [Interface mode]
| System functions: Number of control axes | Up to 64 axes |
| System functions: Control cycle | 0.22 ms, 0.44 ms, 0.88 ms (Select using parameters.) |
| System functions: Control mode | Positioning control, speed control, torque control |
| Operation functions *1 *2: JOG operation | ー |
| Operation functions *1 *2: Incremental feed | ー |
| Operation functions *1 *2: Automatic operation | ー |
| Operation functions *1 *2: Linear interpolation | ー |
| Operation functions *1 *2: Circular interpolation | ー |
| Operation functions *1 *2: Home position return | ー |
| Application functions 1: Electronic gear | ー |
| Application functions 1: Speed units | Command unit/min, command unit/s, r/min (speed units during monitor output) |
| Application functions 1: Acceleration/deceleration | ー |
| Application functions 1: Stop function | Forced stop |
| Application functions 1: Command change | ー |
| Application functions 2 | Torque limit, gain switching, PI-PID switching, absolute position detection system, digital I/O, servo amplifier general I/O, mark detection, event detection |
| Auxiliary function: Monitor | Current command position, current feedback position, speed command, position droop, electrical current command, servo alarm number, external signal status, etc. |
| Auxiliary function: High speed monitor | Current command position, current feedback position, moving speed, feedback moving speed, external signal, electrical current feedback, position droop |
| Auxiliary function: Interrupt | Constant multiplication output of control cycle |
| Auxiliary function: Host PC watchdog | Provided (for the watchdog of the user program CPU) |
| Auxiliary function: Parameter backup | Parameters are saved to the flash ROM. |
| Auxiliary function: Test mode | Servo amplifier tests are easily enabled by connecting MR Configurator2 via a controller. |
| Auxiliary function: Connect/disconnect | Provided |
| Auxiliary function: Sampling | Maximum sampling point: 65536 |
| Auxiliary function: Log | History of start operation, alarms, etc., are recorded. |
| Auxiliary function: Alarm history | Provided |
| Auxiliary function: External forced stop disabled | Provided |
| Board ID | 0 to 3 |
Module specifications
| Servo amplifier connection method | SSCNET III/H |
| Number of SSCNET III/H lines | 2 lines |
| Maximum distance between stations [m] | SSCNET III/H: 100 |
| PERIPHERAL I/F | USB |
| Forced stop input signal (EMI) *4: Number of input points | 1 point |
| Forced stop input signal (EMI) *4: Input method | Positive common/negative common shared type (photocoupler isolation) |
| Forced stop input signal (EMI) *4: Rated input voltage/current | 24 V DC/Approx. 2.4 mA |
| Forced stop input signal (EMI) *4: Operating voltage range | 20.4 V DC to 26.4 V DC (24 V DC +10 %/-15 %, ripple ratio 5 % or less) |
| Forced stop input signal (EMI) *4: ON voltage/current | 17.5 V DC or more/2.0 mA or more |
| Forced stop input signal (EMI) *4: OFF voltage/current | 1.8 V DC or less/0.18 mA or less |
| Forced stop input signal (EMI) *4: Input resistance | Approx. 10 kΩ |
| Forced stop input signal (EMI) *4: Response time | 1 ms or less (OFF to ON, ON to OFF) |
| Forced stop input signal (EMI) *4: Applicable wire size | AWG 28 to AWG 20 (0.08 mm 2 to 0.52 mm 2 ) |
| Number of Simple Motion boards for one computer | 4 |
| Bus specification | PCI Express ® 2.0 |
| Bus specification: Size [mm] | Short size: 105.8 × 128.8 |
| Power supply voltage | 3.3 V DC/12 V DC |
| Current consumption [A] | 3.0/0.5 |
| Mass [kg] | 0.15 |
| Note | 1. Make sure to induce an airflow in the PC case of the host controller that the MR-MC341 position board is installed. For details, refer to "MR-MC200/MR-MC300 Series Position Board User's Manual (Details)". |
Downloads & documentation
Official documents from Mitsubishi Electric (Factory Automation), downloaded directly from the manufacturer.
Data sheets & manuals
More Mitsubishi Electric (Factory Automation) parts
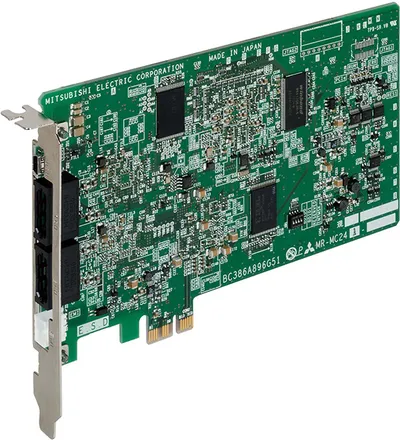 Available on requestMR-MC240 Mitsubishi Motion controller Embedded Type Servo System Controller
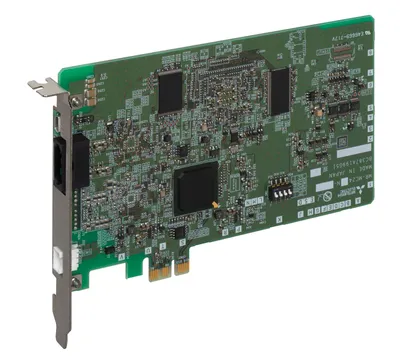 Available on requestMR-MC240N Mitsubishi Motion controller Embedded Type Servo System ControllerAvailable on requestMR-MC241 Mitsubishi Motion controller Embedded Type Servo System Controller
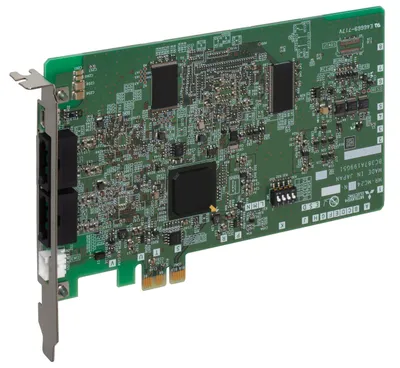 Available on requestMR-MC241N Mitsubishi Motion controller Embedded Type Servo System Controller
 Available on requestMR-MT2010 Mitsubishi Motion controller Network-related products
 Available on requestMR-MT2100 Mitsubishi Motion controller Network-related products
 Available on requestMR-MT2200 Mitsubishi Motion controller Network-related products
 Available on requestMR-MT2300 Mitsubishi Motion controller Network-related products