Części Beckhoff
Beckhoff
EL9562EtherCAT Terminal, power supply, 24 V DC, 2 x output 24 V DC, 0.2 A, electrically isolated
Beckhoff
EL9562-0015EtherCAT Terminal, power supply, 24 V DC, 2 x output 15 V DC, 0.3 A, electrically isolated
Beckhoff
EL8601-8411EtherCAT Terminal, 12-channel multi-interface, 8 x DI, 1 x CNT, 4 x DO, 2 x PWM, 1 x AI, 1 x AO, 1 x ENC AB
Beckhoff
EL7221-9014EtherCAT Terminal, 1-channel motion interface, servomotor, 48 V DC, 8 A, OCT, suitable for STO applications
Beckhoff
EL7211-9014EtherCAT Terminal, 1-channel motion interface, servomotor, 48 V DC, 4.5 A, OCT, suitable for STO applications
Beckhoff
EL7201-9014EtherCAT Terminal, 1-channel motion interface, servomotor, 48 V DC, 2.8 A, OCT, suitable for STO applications
Beckhoff
EL7037EtherCAT Terminal, 1-channel motion interface, stepper motor, 24 V DC, 1.5 A, with incremental encoder
Beckhoff
EL7047EtherCAT Terminal, 1-channel motion interface, stepper motor, 48 V DC, 5 A, vector control, with incremental encoder
Beckhoff
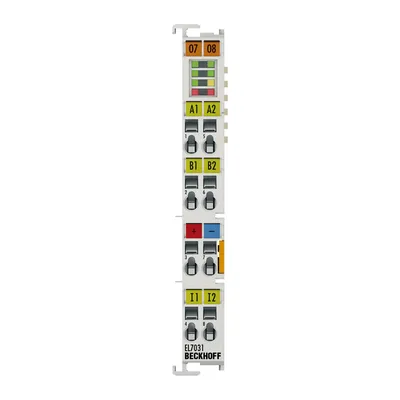
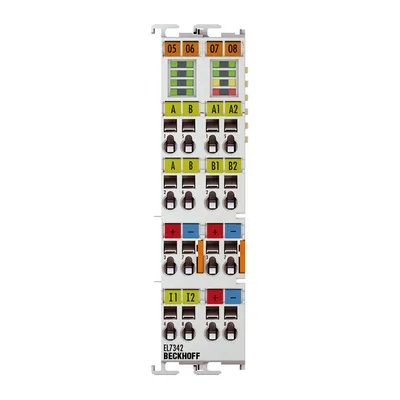
EL7041EtherCAT Terminal, 1-channel motion interface, stepper motor, 48 V DC, 5 A, with incremental encoder
Beckhoff
EL7411EtherCAT Terminal, 1-channel motion interface, BLDC motor, 48 V DC, 4.5 A, with incremental encoder